 1 / 10
Specifications
- Stroke
- 30x30x20mm XYZ
- Country of Origin
- China
About this product
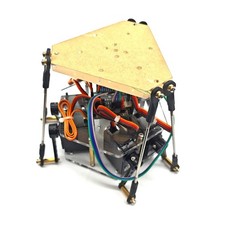
Six degrees of freedom platform motion parameters: 6DOF-PID-S Size: 180*180*180mm Weight: 0.8Kg Speed: 20mm/s Motion Range: X:±30mm Y:±30mm Z:±20mm Roll: ±15° Pitch:±15° Yaw: ±30° 6DOF-PID-M Size: 160*160*160mm X:±42mm Y:±42mm Z:±32mm Roll: ±20° Pitch:±20° Power requirement: USB 5V-1A, 2A or above is recommended, fast…Read full descriptionShow less
Six degrees of freedom platform motion parameters: 6DOF-PID-S Size: 180*180*180mm Weight: 0.8Kg Speed: 20mm/s Motion Range: X:±30mm Y:±30mm Z:±20mm Roll: ±15° Pitch:±15° Yaw: ±30°
6DOF-PID-M Size: 160*160*160mm X:±42mm Y:±42mm Z:±32mm Roll: ±20° Pitch:±20° Power requirement: USB 5V-1A, 2A or above is recommended, fast speed. The accessory does not have a power supply. Overall: main body (6 servos, frame, connecting rod), motion control board.
*6-axis gyroscope control board; *controllers must be purchased separately
Source code is not provided. The Stewart platform parallel mechanism has become a research hotspot of space mechanism because of its large rigidity, strong bearing capacity and unacceptable position error. At present, Stewart platform parallel mechanism has been widely used in aviation, aerospace, subsea operations, underground mining, manufacturing and assembly industries. Although the practical application and theoretical research of parallel mechanisms have achieved a lot of research results, there are still some challenging problems in kinematics, singularity and dynamics. For example, the solution of the Jacobian matrix with less degrees of freedom parallel mechanism is not yet available. A unified method; seeking an algorithm that can find all the solutions of the positive solution of the parallel mechanism position; seeking a solution to the efficient inverse dynamic problem. The Jacobian matrix is a major component of the Stewart platform parallel mechanism, which represents a mapping from the input joint to the end effector output.
Description written by a seller of this product on eBay. Store, shipping, payment and contact text has been removed. Check each offer for that seller's own terms.
Price history
Lowest price available each day, tracked since Oct 7, 2026 (22 days).
- Current lowest
- None available
- Previous price
- No change yet
- Lowest recorded
- $195.00
- Highest recorded
- $195.00
- Trend
- Not enough data
The lowest price for all conditions has not changed in this period, so there is no trend to chart yet.
History is built only from prices this site observed, starting the day tracking began; nothing is estimated or back-filled. Each point is the lowest price among the offers available that day. Shipping, duties and taxes are not included.